Electrical engineering · University at Buffalo

Byron
Bradley.

Electronics repair, embedded firmware,
and circuit measurements.

I'm an electrical engineering junior. My work spans diagnosing console power faults, writing robot navigation software, and testing circuits at the bench.

01 / Selected work

Projects & repair work

Notes, source code, and results.

Electronics repair & resale

Bytronyx

Finding the fault.
Checking the repair.

I bought, repaired, and resold game consoles and controllers. My repair log records the symptoms, diagnostic checks, replacement parts, functional tests, and costs.

Items in the log
248
Repaired items
221

Multimeter / Soldering / Hot-air rework / DC supply
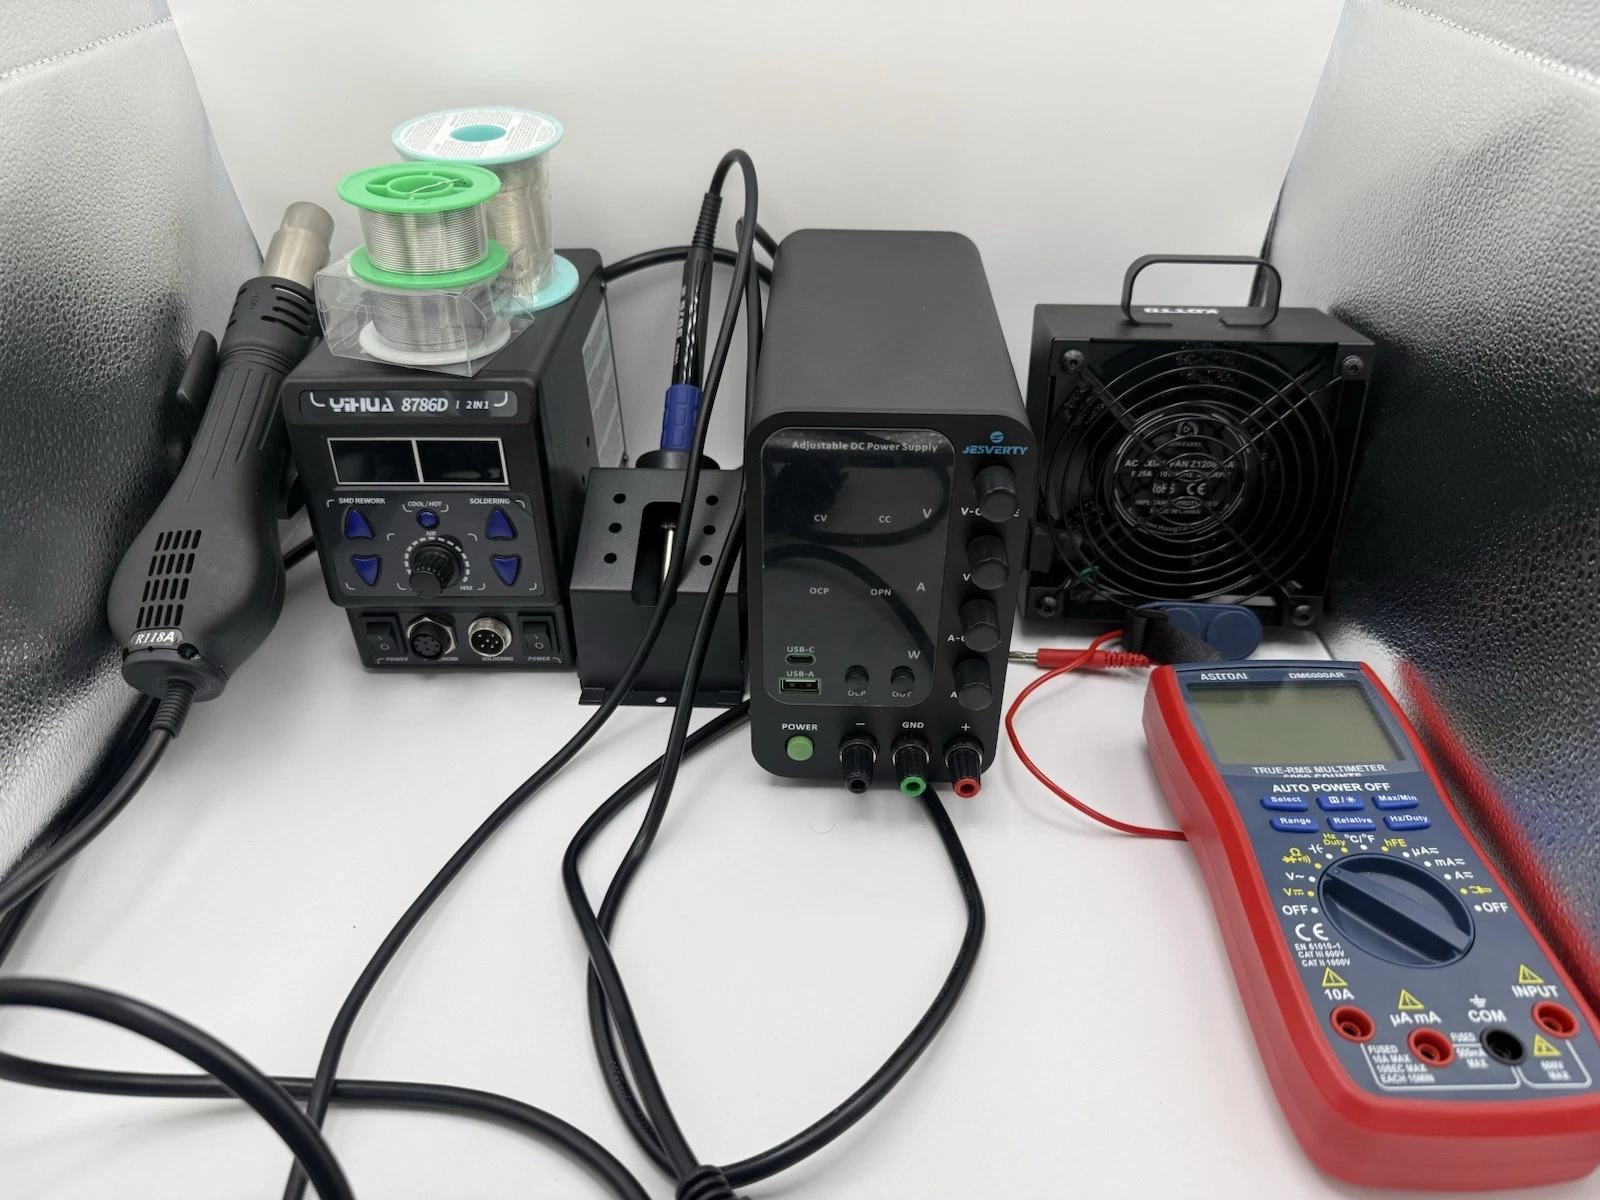
Soldering and hot-air station, DC supply, and multimeter from my electronics repair setup
Equipment from my repair setup.
Repair example: Xbox 360 power fault

The console would not boot and reported error 0001. A known working power supply produced the same fault. I found a drain-to-source short on a MOSFET in the motherboard voltage regulator.

After replacing the MOSFET, I checked that the short was gone and measured 12.1 V on the 12 V input rail with the console running. Startup and gameplay checks did not reproduce the fault.

Read repair record EX-136
Embedded programming · IEEE at UB

Maze navigation

A map built one wall reading at a time.

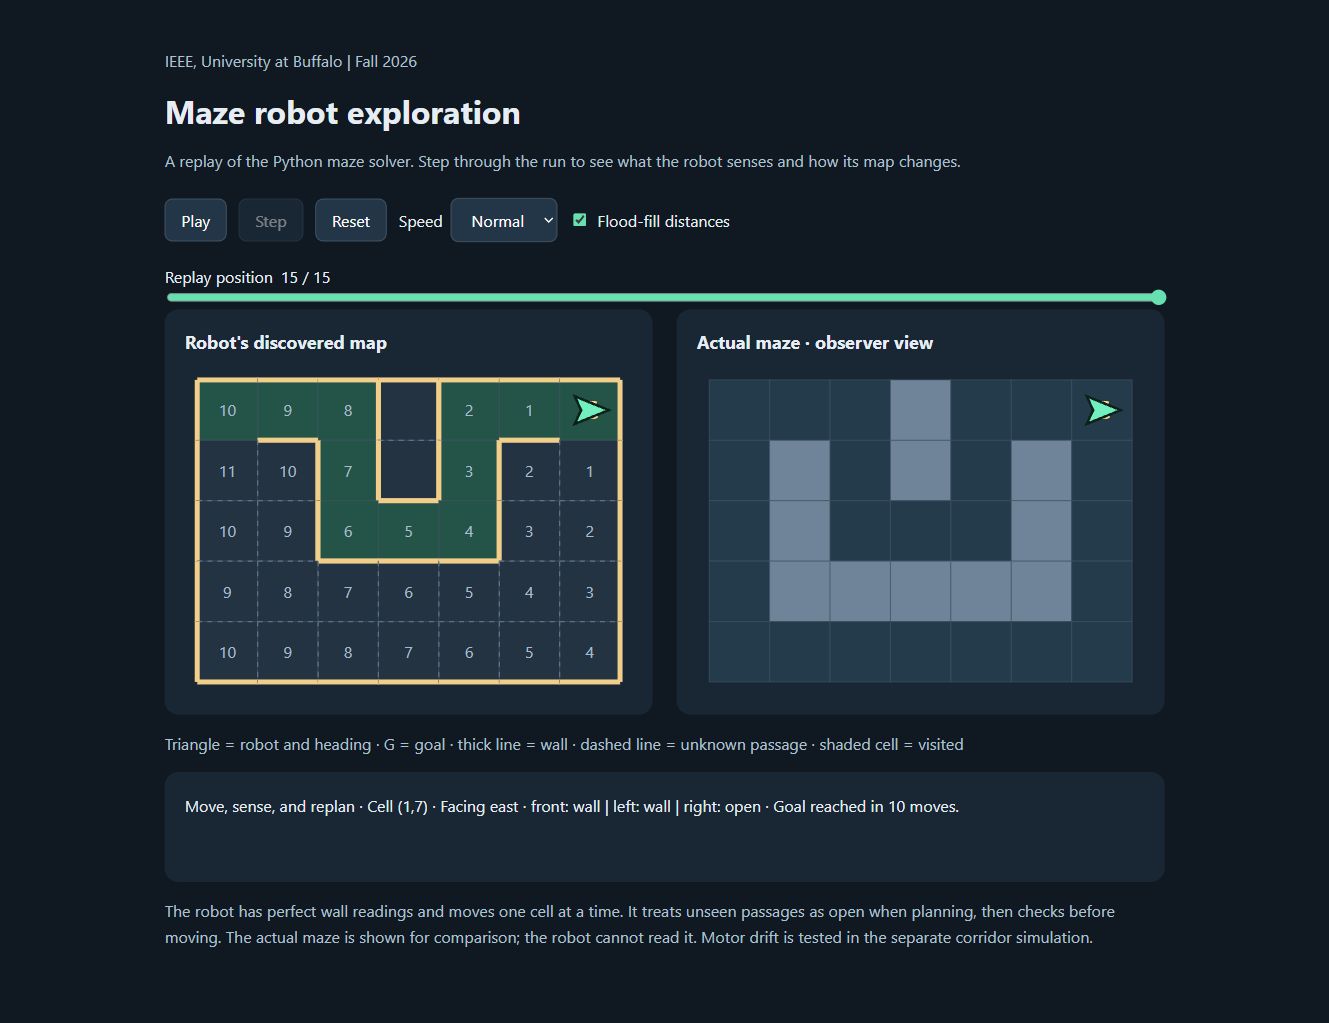
My part of this IEEE project is the Python simulator and C++ firmware for an Arduino Nano 33 BLE Sense Rev2. The planner maps wall readings and uses flood-fill to find its next move.

The firmware includes an 8 × 8 map, ultrasonic sensing, PWM motor commands, and fault-stop states. Automated checks compare the Python and C++ planners across 200 seeded partial maps.

Python / C++ / Arduino / GitHub Actions

Maze simulation showing the robot's discovered map beside the reference mazeOpen interactive replay
Python simulation. The firmware compiles; assembly, calibration, and physical trials are still ahead.
Planning and movement constraints

Unseen passages count as open for planning, but the robot must confirm an opening before moving through it. Each wall update is mirrored in the neighboring cell.

Physical moves use timers. Wheel slip, load, and battery voltage can change the distance traveled. Motion stays disabled until the timing constants have been measured and calibration is enabled.

Read the design notes

Python & computer vision

Inventory barcode reader

From a label image to a timestamped record.

A Python tool that reads inventory barcodes and logs scan events to CSV. OpenCV handles the images and ZXing-C++ decodes the barcodes. My code handles scale retries, repeated readings, camera capture, and logging.

Python / OpenCV / ZXing-C++ / Raspberry Pi target

Generated-image development tests

54/60Initial exact reads
60/60With scale retries

Followed by 100/100 on additional generated cases. Camera accuracy and frame rate have not yet been measured on the planned Raspberry Pi hardware.

What changed after testing

The initial decoder missed five test images and returned an extra candidate on one. I added retries at 2× and 3× image size, then a second-scale check when a frame produced multiple candidates.

Retries take more processing time, and confirmation can discard a real label. Physical trials will need to measure those tradeoffs with glare, focus, distance, and motion blur.

University at Buffalo · Circuit labs

Analog & mixed-signal circuits

Built and tested delta-sigma A/D and R–2R ladder D/A circuits, along with low-pass, high-pass, and band-pass filters.

I measured gain, cutoff frequency, and phase response with an oscilloscope and function generator, then compared the measurements with LTspice simulations.

LTspice / Oscilloscope / Function generator / Breadboarding

02 / Background

Education & experience

University at Buffalo

B.S. Electrical Engineering

Expected May 2028
IEEE Student Member

My interests are in hardware, embedded systems, and test engineering. Electronics repair gave me practical experience with fault isolation, component replacement, and checking a device after the work is done.

View full résumé

FedEx

May 2025–present

Package Handler Trainer

Trained approximately 40 handlers in scanning, unloading, and safe work procedures. Supervised groups of about 20, assigned tasks, and addressed safety issues.

Stonehill's

May–August 2024

Event Technician

Set up and tested speakers, mixers, microphones, and lighting. Routed power and signal cables and resolved equipment faults during setup and live events.

Programming
C, C++, Python, MATLAB
Electronics
LTspice, KiCad, Arduino,
soldering & hot-air rework
Test equipment
Oscilloscope, function generator,
multimeter, DC power supply
Development
Git, Linux, GitHub Actions

03 / Contact

Let's talk engineering.

I'm seeking a Summer 2027 internship in hardware,
embedded systems, or test engineering.